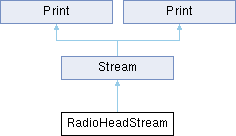
Arduino Stream which is using the RadioHead library to send and receive data. We use the driver API directly.
More...
#include <RadioHeadStream.h>
|
| bool | receive () |
| | Copies the next received message into the buffer.
|
| void | send () |
Arduino Stream which is using the RadioHead library to send and receive data. We use the driver API directly.
In TX_MODE the written data is collected and sent in messages of maxMessageLength() bytes: call flush() to send a partially filled message. In RX_MODE each received message is buffered, so that it can be read in chunks of any size.
- Note
- Supported only on Arduino platforms with support for the RadioHead library and the related hardware (e.g. ESP32 with LoRa, nRF24L01, etc.)!
-
Requires: 👉 https://www.airspayce.com/mikem/arduino/RadioHead/
- Author
- Phil Schatzmann
- Copyright
- GPLv3
◆ RadioHeadStream()
◆ available()
◆ availableForWrite()
| int availableForWrite |
( |
| ) |
|
|
inlineoverridevirtual |
Reimplemented from Print.
◆ begin() [1/2]
◆ begin() [2/2]
◆ end()
◆ flush()
Sends the buffered data.
Reimplemented from Print.
◆ operator bool() [1/2]
◆ operator bool() [2/2]
◆ peek()
◆ read()
◆ readBytes()
| size_t readBytes |
( |
uint8_t * | data, |
|
|
size_t | len ) |
|
inlineoverridevirtual |
◆ receive()
Copies the next received message into the buffer.
◆ send()
◆ setDriver()
| void setDriver |
( |
RHGenericDriver & | driver | ) |
|
|
inline |
◆ setMode()
Defines if we send (TX_MODE) or receive (RX_MODE).
◆ write() [1/2]
| size_t write |
( |
const uint8_t * | data, |
|
|
size_t | len ) |
|
inlineoverridevirtual |
Reimplemented from Print.
◆ write() [2/2]
| size_t write |
( |
uint8_t | c | ) |
|
|
inlineoverride |
◆ _timeout
◆ buffer
◆ mode
◆ p_driver
| RHGenericDriver* p_driver = nullptr |
|
protected |
The documentation for this class was generated from the following file:
 1.15.0